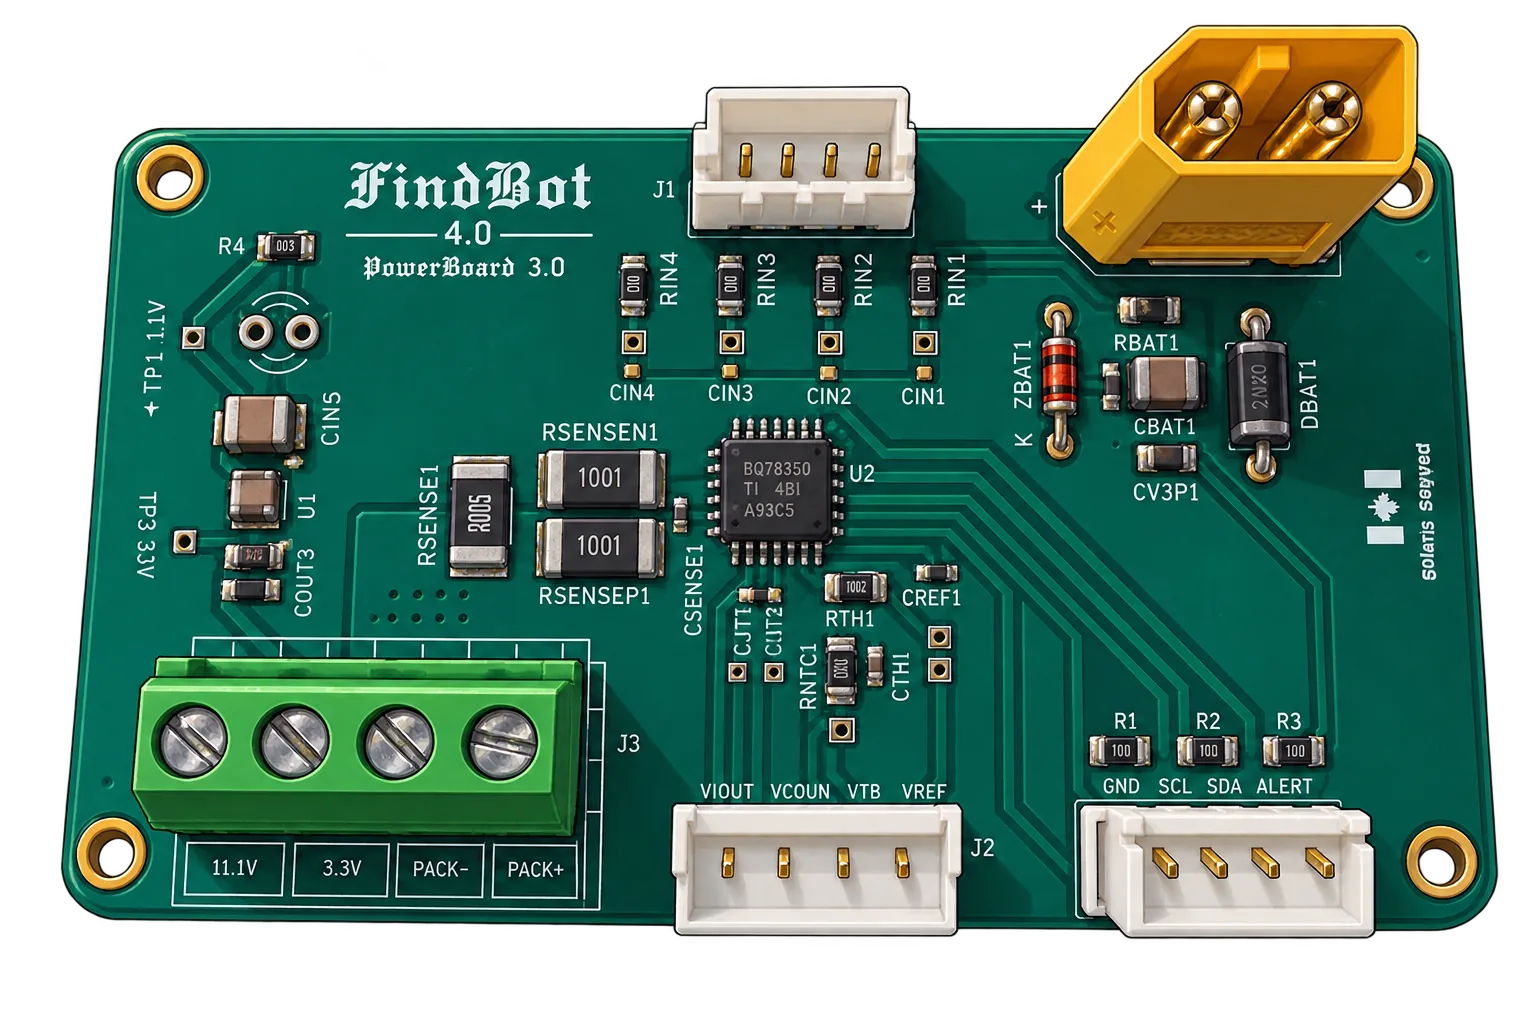
 Battery Management SystemCustom PCBFeatured ProjectDesigned + brought up a 4-layer BMSfor monitoring + safety on 11.1V LiPoClick to read how I built it (new tab)
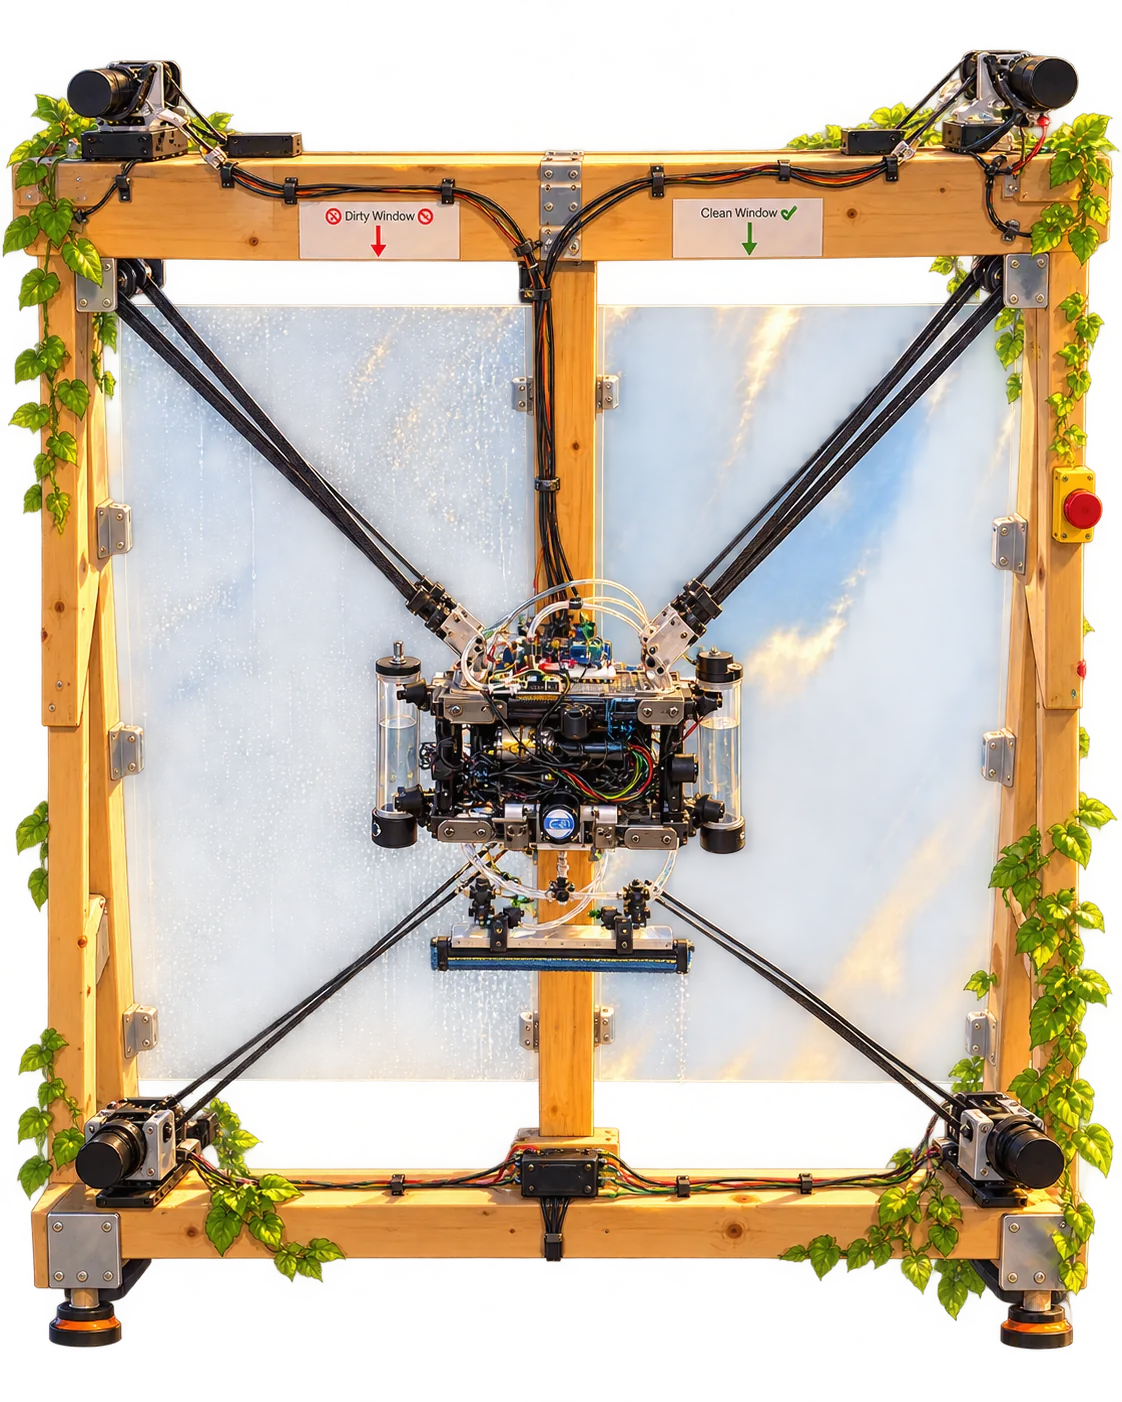
 Skyscraper Cleaning RobotCable Driven RobotFeatured ProjectBuilt controls + electrical systemsfor a 4-motor cable-driven robotClick to read how I built it (new tab)
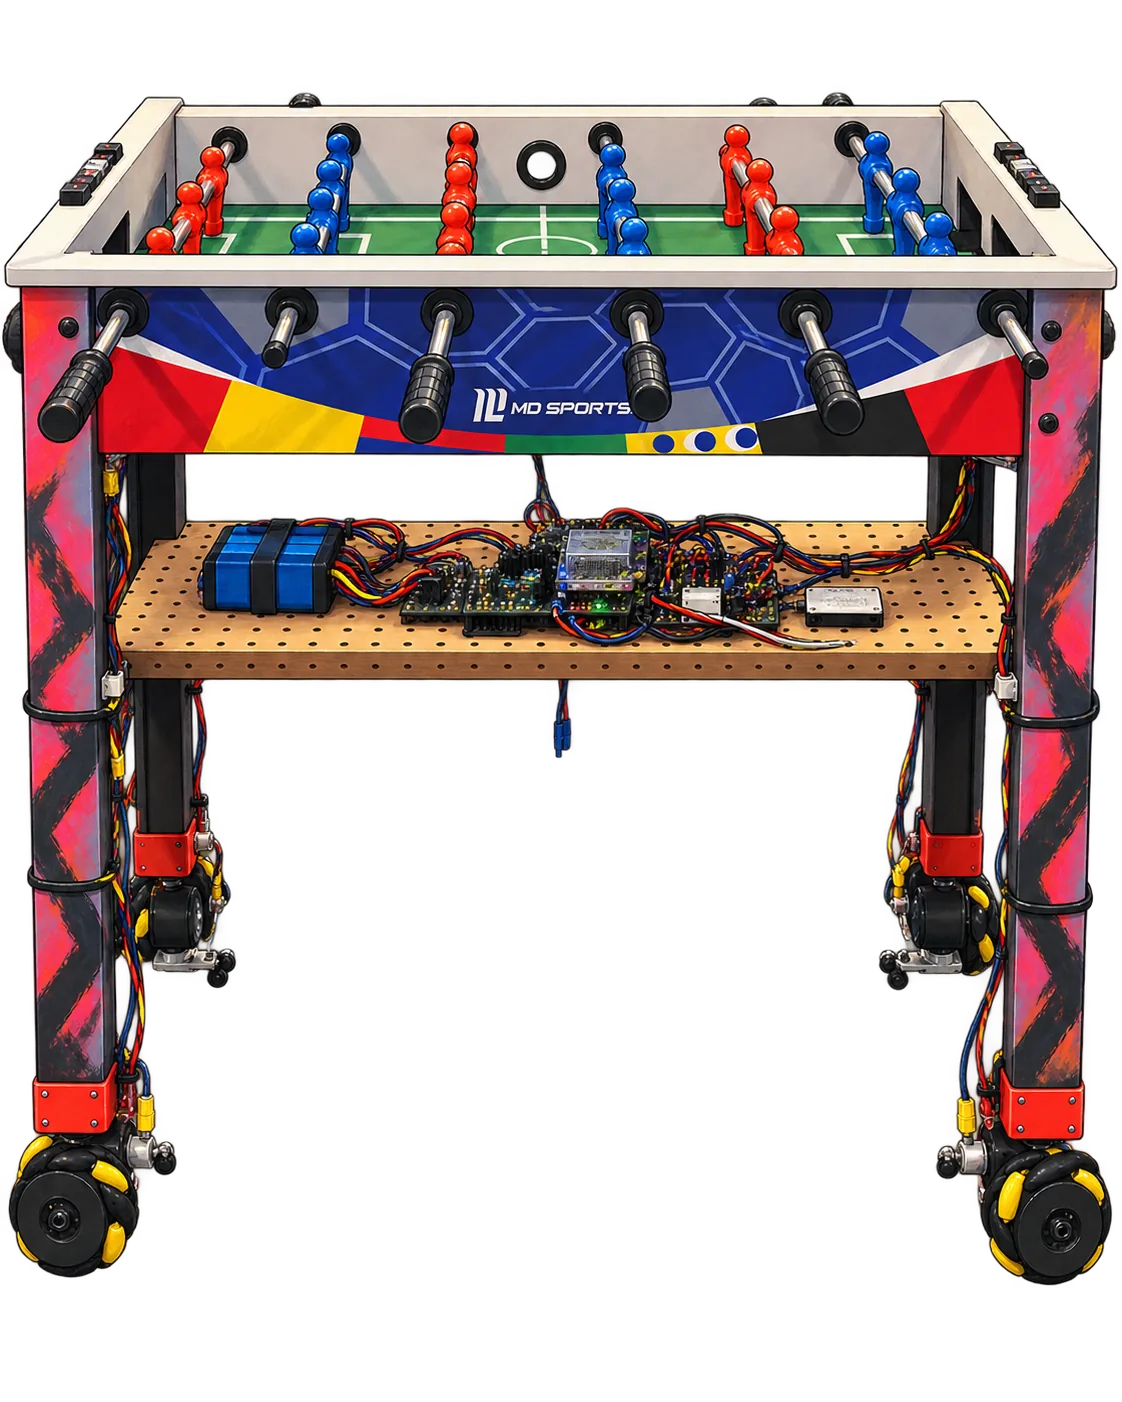
 Foos-on-WheelsThis One Was for FunFeatured ProjectPut a foosball tableon radio controlled motorized wheelsClick to watch it in action (new tab)
Outside of robots
- Hosted Socratica for a semester, a weekly co-working session for people working on passion projects.
- Started Scratchpad, Socratica’s Chicago node, hosted cozy weekly co-working nights on Tuesdays (still running!).
Where I Think I Fit at Pantograph
Generalist Robotics EngineerThe Robotics Software Engineer role is probably the closest fit, but I think my biggest strength on a small team is being able to work across the whole robot.
End-to-end robot building
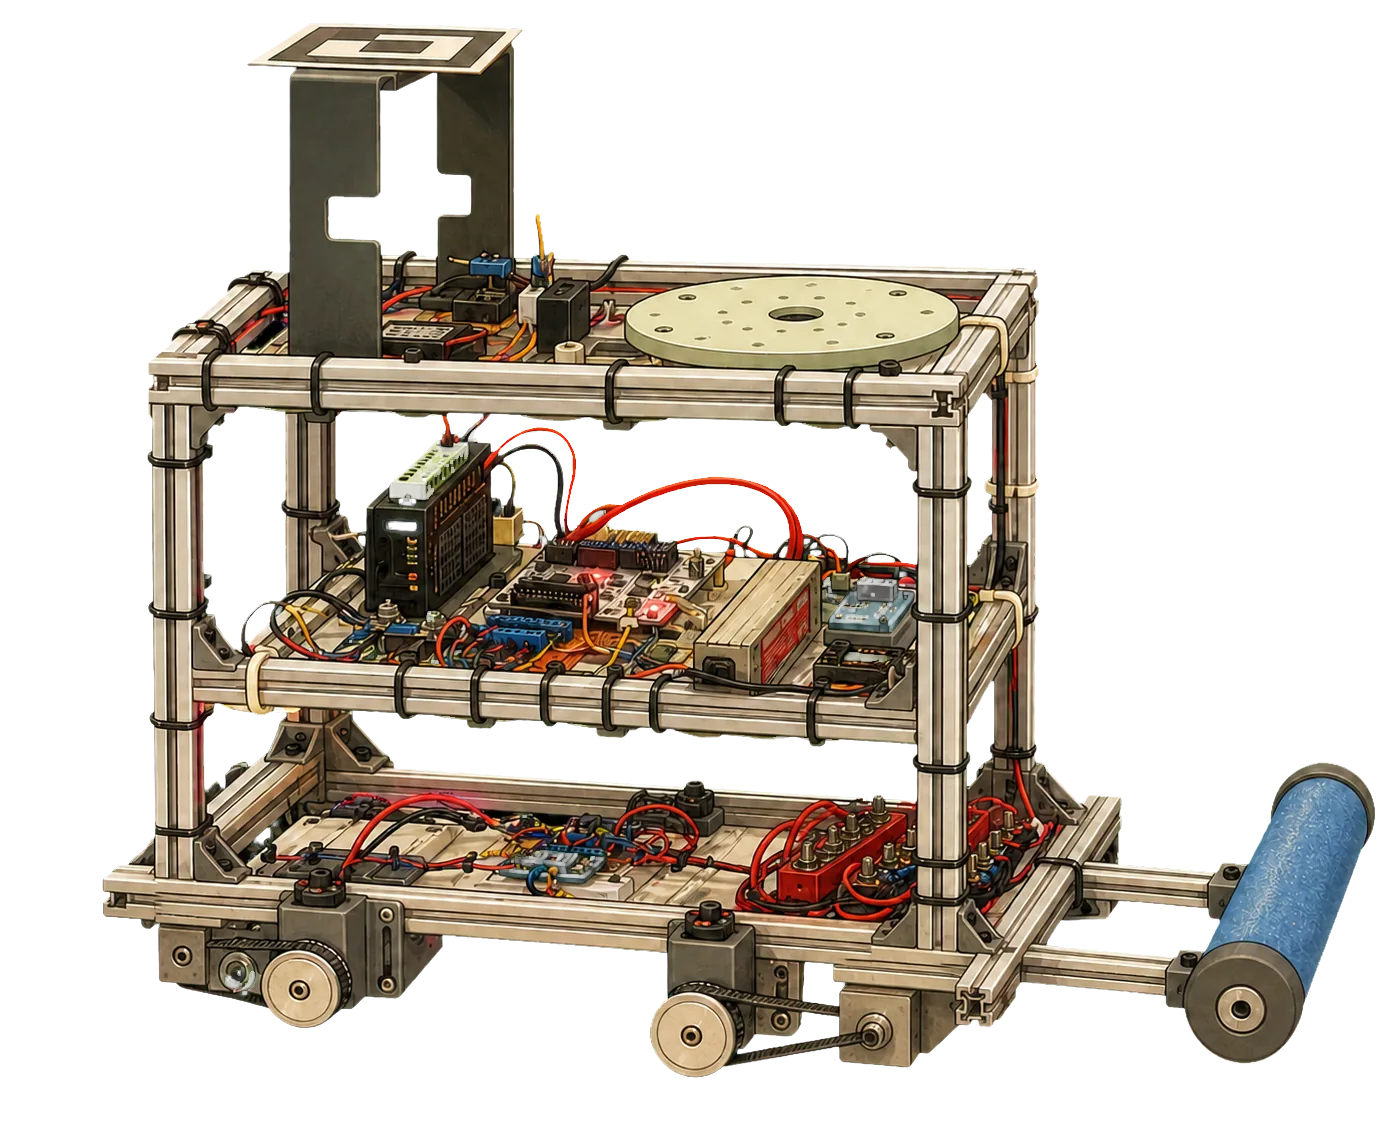
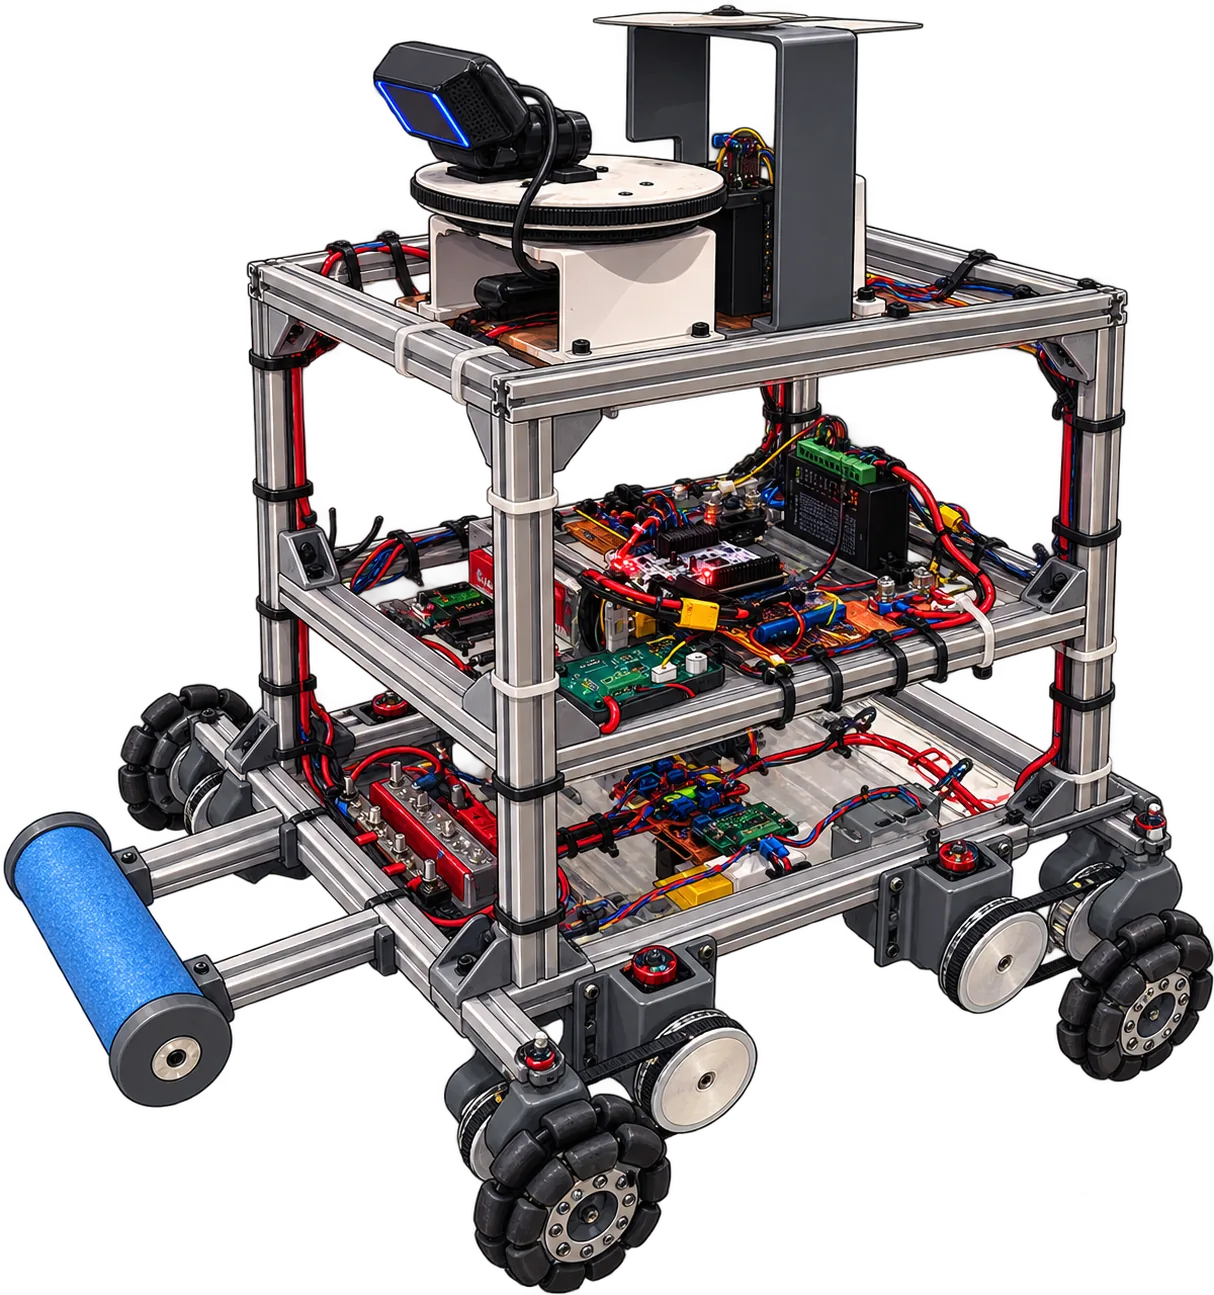
Built FindBot from scratch across 4 revisions: mechanical design, drivetrain, custom PCB, STM32 firmware, Pi/Linux software + autonomy.
Core robot software
Built closed-loop motor fault detection + recovery at Zenblen, cutting motor downtime 70%; wrote FindBot’s motor, sensor + communications firmware.
Electrical + hardware
Designed 3 PCBs for production robots at Gastronomous + a custom 4-layer, 9A BMS/power PCB for FindBot.
Testing + reliability
Built robot debugging tools, fault recovery + telemetry; iterated FindBot through real failures like bent drivetrain parts, belt skipping + wheel scrub.
Data collection + robot infrastructure
Built Zenblen's 4-camera Pi/GStreamer recording system, automatic camera ID + remote control, fleet telemetry at Gastronomous, and the teleop data pipeline for this demo.
Perception + autonomy
Deployed vision models on production robots at Zenblen + Gastronomous; trained and deployed FindBot’s behavior-cloning policy on the real robot.
Mechanical + system integration
Designed + fabricated FindBot’s chassis, belt drivetrain + camera turret; built controls/electrical systems for a synchronized 4-motor cable robot.
Software engineering
4 software internships building full-stack production software, including an LLM assistant on a 60M-user platform (Python, Rust, JavaScript/TypeScript).
Why I Want To Work at Pantograph
I think cheap, generally intelligent robots are going to be a really big deal
I like the bet Pantograph is making - that getting there means building a lot of simple robots and getting them out in the world to collect experience
I also really like that you're building everything in house, robots and models. That's exactly the type of work that reeeeeeally excites me!
Demo Video: I Trained a Robot (I Built From Scratch) to Autonomously Push a Block Into a Goal Using Teleoperated Demonstrations(3 mins long)
View demo code↗